报告详情
Vehicle Trajectory Enhanced Map-matching Method for Low Frequency GPS Data
编号:1359
访问权限:仅限参会人
更新:2021-12-03 10:48:39 浏览:221次
张贴报告
摘要
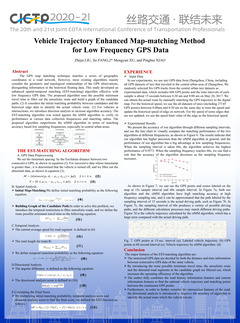
GPS map match technique matches a series of geographic coordinates to the road network. However, most existing algorithms consider mainly the geometric and topological relationships of the GPS observations, while the information in the historical floating data remains untouched. In this paper, we develop an enhanced spatial-temporal matching (EST-matching) algorithm effective with low frequency GPS data. The proposed algorithm improves the map-matching technique in the following aspects: (1) The proposed algorithm uses the possible minimum travel time to filter out the unrealistic route and build graph of the candidate paths. (2) Considered the initial matching probability between candidates and the historical data of edge to identify the actual route which the vehicle travel. (3) For vehicles driving at intersections, we introduce direction analysis to increase the algorithm accuracy. The developed (EST-matching) algorithm is tested against the stMM algorithm over a series of real-world data to verify its performance at various data collection frequencies and matching radius. Experiments show that the proposed algorithm outperforms the stMM algorithm in terms of matching accuracy based low sampling frequencies, especially in central urban area.
关键词
CICTP
报告人

Jie Fang
Fuzhou University稿件作者
全部评论
重要日期
-
会议日期
12月17日
2021
至12月20日
2021
-
12月16日 2021
报告提交截止日期
-
12月24日 2021
注册截止日期
主办单位
Chinese Overseas Transportation Association
Chang'an University
Chang'an University
联系方式
- CICTP2020-21 Conference Organizing Committee
- ci******@gmail.com
历届会议
-
2025年07月22日 中国 广州市(Guangzhou)
第25届COTA国际交通科技年会 -
2024年07月23日 中国 Shenzhen
第24届海外华人交通协会国际交通科技年会(CICTP 2024) -
2023年07月15日 中国 北京(Beijing)
海外华人交通协会国际交通科技年会 -
2022年07月08日 中国 Changsha
The 22nd COTA International Conference of Transportation Professionals -
2019年07月06日 中国 南京
The 19th COTA International Conference of Transportation Professionals -
2018年07月05日 中国 Haidian District
18th COTA International Conference of Transportation Professionals -
2016年07月06日 中国 Shanghai, China
The 16th COTA conference International Conference of Transportation Professionals -
2013年08月14日 中国 深圳市
International Conference of Transportation Professionals


发表评论