报告详情
Enhanced ERFNet Decoder for Road Segmentation Model
编号:1851
访问权限:仅限参会人
更新:2021-12-12 17:33:08
浏览:220次
张贴报告
摘要
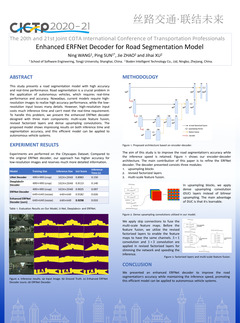
This study presents a road segmentation model with high accuracy and real-time performance. Road segmentation is a crucial problem in the application of autonomous vehicles, which requires real-time performance and accuracy. Nowadays, current models require high-resolution images to realize high accuracy performance, while the low-resolution losses many details. However, high-resolution costs much inference time and can’t meet the real-time requirement. To handle this problem, on basis of Efficient Residual Factorized ConvNet (ERFNet), we insert the feature fusion and enhance its upsampling blocks, which capture more road’s edge information and achieve higher accuracy. This enhanced ERFNet decoder is designed with three main components: multi-scale feature fusion, revised factorized layers and dense upsampling convolutions. The model is based on the encoder-decoder architecture, and the encoder network is Efficientnet-B1. The proposed model shows impressing results on both inference time and segmentation accuracy, and this efficient model can be applied to autonomous vehicle systems.
关键词
CICTP
报告人

Ping Sun
Tongji University稿件作者
全部评论
重要日期
-
会议日期
12月17日
2021
至12月20日
2021
-
12月16日 2021
报告提交截止日期
-
12月24日 2021
注册截止日期
主办单位
Chinese Overseas Transportation Association
Chang'an University
Chang'an University
联系方式
- CICTP2020-21 Conference Organizing Committee
- ci******@gmail.com
历届会议
-
2025年07月22日 中国 广州市(Guangzhou)
第25届COTA国际交通科技年会 -
2024年07月23日 中国 Shenzhen
第24届海外华人交通协会国际交通科技年会(CICTP 2024) -
2023年07月15日 中国 北京(Beijing)
海外华人交通协会国际交通科技年会 -
2022年07月08日 中国 Changsha
The 22nd COTA International Conference of Transportation Professionals -
2019年07月06日 中国 南京
The 19th COTA International Conference of Transportation Professionals -
2018年07月05日 中国 Haidian District
18th COTA International Conference of Transportation Professionals -
2016年07月06日 中国 Shanghai, China
The 16th COTA conference International Conference of Transportation Professionals -
2013年08月14日 中国 深圳市
International Conference of Transportation Professionals


发表评论