报告详情
Precise Occupancy Grid Map Generation with only FMCW Radar
编号:1902
访问权限:仅限参会人
更新:2021-12-14 17:22:21
浏览:280次
张贴报告
摘要
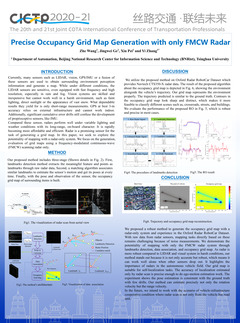
As is more robust compared to LIDAR, visual system, GPS and other proprioceptive sensors, radars operate well to detect objects at a long-range under different weather and lighting condition. The occupancy grid map is suitable for a high-level abstract representation of the environment, which is common in the robotics field. In this paper, we proposed a robust and precise radar-only algorithm of the occupancy grid map. Using the FMCW radar scan as an input, we first extract landmarks from noise measurements with minimal false positives and avoiding the detection of ghost objects. To estimate the radar’s relative motion, we associate with different landmarks corresponding to the same location at different times. With the pose information of radar and radar’s measurement, finally, we generate an occupancy grid map based on the inverse sensor model fit with radar’s characters. We experiment with our method in the Oxford Radar RobotCar Dataset, and the result shows map’s contours are sharp and distinct and our method can work well alone when other sensors drop out. Our grid map is also suitable for self-localization tasks that is precise enough for ego-motion estimation.
关键词
CICTP
报告人

Yi Zhang
Tsinghua University稿件作者
全部评论
重要日期
-
会议日期
12月17日
2021
至12月20日
2021
-
12月16日 2021
报告提交截止日期
-
12月24日 2021
注册截止日期
主办单位
Chinese Overseas Transportation Association
Chang'an University
Chang'an University
联系方式
- CICTP2020-21 Conference Organizing Committee
- ci******@gmail.com
历届会议
-
2025年07月22日 中国 广州市(Guangzhou)
第25届COTA国际交通科技年会 -
2024年07月23日 中国 Shenzhen
第24届海外华人交通协会国际交通科技年会(CICTP 2024) -
2023年07月15日 中国 北京(Beijing)
海外华人交通协会国际交通科技年会 -
2022年07月08日 中国 Changsha
The 22nd COTA International Conference of Transportation Professionals -
2019年07月06日 中国 南京
The 19th COTA International Conference of Transportation Professionals -
2018年07月05日 中国 Haidian District
18th COTA International Conference of Transportation Professionals -
2016年07月06日 中国 Shanghai, China
The 16th COTA conference International Conference of Transportation Professionals -
2013年08月14日 中国 深圳市
International Conference of Transportation Professionals


发表评论