报告详情
A Model Predictive Controller for Automated Lane Change Maneuver with Multi-constraints
编号:2020
访问权限:仅限参会人
更新:2021-12-14 17:11:32
浏览:267次
张贴报告
摘要
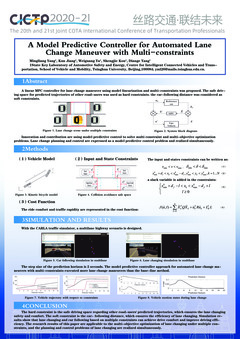
Automated lane change is a challenging task due to simultaneous longitudinal and lateral vehicle control in high-speed dynamic environments. To guarantee safe and efficient lane change, a model predictive controller considering multi-constrains is presented in this paper. Safe driving space for the predictive driving environment and physical vehicle limitations is considered as a hard constraint to ensure safety. Inter-vehicle car-following distance is considered as a soft constraint to improve traffic efficiency. The algorithm proceeds to solve a convex quadratic program to obtain the optimal control input. Simulation with CARLA simulator proves that the lane changing and car-following model with the constraints improves the driving comfort and lane change efficiency. Combined with lane changing safety distance constraint and car following safety distance constraint, this algorithm considers dynamic characteristics of vehicles, solves the problem of no solution of trajectory planning of other models, and realizes the adaptive adjustment of lane changing safety and efficiency in different scenarios.
关键词
CICTP
报告人

Mingliang Yang
Tsinghua University稿件作者
全部评论
重要日期
-
会议日期
12月17日
2021
至12月20日
2021
-
12月16日 2021
报告提交截止日期
-
12月24日 2021
注册截止日期
主办单位
Chinese Overseas Transportation Association
Chang'an University
Chang'an University
联系方式
- CICTP2020-21 Conference Organizing Committee
- ci******@gmail.com
历届会议
-
2024年07月23日 中国 Shenzhen
第24届海外华人交通协会国际交通科技年会(CICTP 2024) -
2022年07月08日 中国 Changsha
The 22nd COTA International Conference of Transportation Professionals -
2019年07月06日 中国 南京
The 19th COTA International Conference of Transportation Professionals -
2018年07月05日 中国 Haidian District
18th COTA International Conference of Transportation Professionals -
2016年07月06日 中国 Shanghai, China
The 16th COTA conference International Conference of Transportation Professionals -
2013年08月14日 中国 深圳市
International Conference of Transportation Professionals


发表评论